mirror of
https://github.com/bulletphysics/bullet3.git
synced 2026-10-20 15:50:56 +00:00
Merge branch 'master' of github.com:erwincoumans/bullet3 into master
This commit is contained in:
 erwin coumans
@@ -1,5 +1,36 @@
|
||||
SUBDIRS( InverseDynamics BulletRoboticsGUI BulletRobotics obj2sdf Serialize ConvexDecomposition HACD GIMPACTUtils )
|
||||
OPTION(BUILD_INVERSE_DYNAMIC_EXTRA "Build InverseDynamic extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_GUI_EXTRA "Build BulletRoboticsGUI extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_BULLET_ROBOTICS_EXTRA "Build BulletRobotics extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_OBJ2SDF_EXTRA "Build obj2sdf extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_SERIALIZE_EXTRA "Build Serialize extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_CONVEX_DECOMPOSITION_EXTRA "Build ConvexDecomposition extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_HACD_EXTRA "Build HACD extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
OPTION(BUILD_GIMPACTUTILS_EXTRA "Build GIMPACTUtils extra module, only applied when BUILD_EXTRAS is ON" ON)
|
||||
|
||||
IF(BUILD_INVERSE_DYNAMIC_EXTRA)
|
||||
SUBDIRS( InverseDynamics )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_GUI_EXTRA)
|
||||
SUBDIRS( BulletRoboticsGUI )
|
||||
ENDIF()
|
||||
IF(BUILD_BULLET_ROBOTICS_EXTRA)
|
||||
SUBDIRS( BulletRobotics )
|
||||
ENDIF()
|
||||
IF(BUILD_OBJ2SDF_EXTRA)
|
||||
SUBDIRS( obj2sdf )
|
||||
ENDIF()
|
||||
IF(BUILD_SERIALIZE_EXTRA)
|
||||
SUBDIRS( Serialize )
|
||||
ENDIF()
|
||||
IF(BUILD_CONVEX_DECOMPOSITION_EXTRA)
|
||||
SUBDIRS( ConvexDecomposition )
|
||||
ENDIF()
|
||||
IF(BUILD_HACD_EXTRA)
|
||||
SUBDIRS( HACD )
|
||||
ENDIF()
|
||||
IF(BUILD_GIMPACTUTILS_EXTRA)
|
||||
SUBDIRS( GIMPACTUtils )
|
||||
ENDIF()
|
||||
|
||||
|
||||
#Maya Dynamica plugin is moved to http://dynamica.googlecode.com
|
||||
|
||||
31
README.md
31
README.md
@@ -7,8 +7,11 @@ This is the official C++ source code repository of the Bullet Physics SDK: real-
|
||||
|
||||
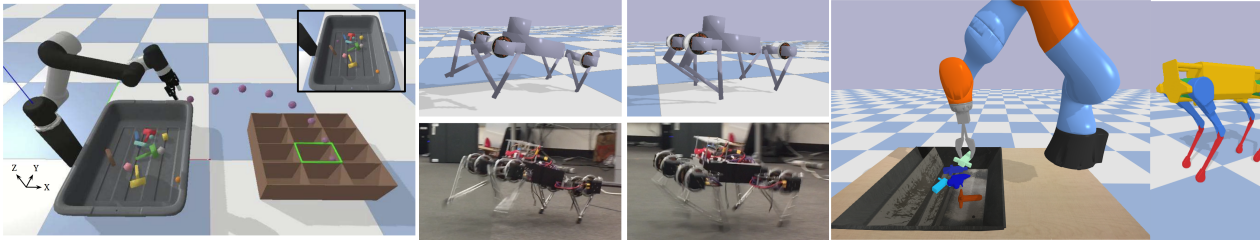
|
||||
|
||||
## Issues ##
|
||||
The Issue tracker was flooded with support questions and is closed until it is cleaned up. Use the [PyBullet forums](http://pybullet.org) to discuss with others.
|
||||
|
||||
## PyBullet ##
|
||||
New in Bullet 2.85: pybullet Python bindings, improved support for robotics and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
It is highly recommended to use PyBullet Python bindings for improved support for robotics, reinforcement learning and VR. Use pip install pybullet and checkout the [PyBullet Quickstart Guide](https://docs.google.com/document/d/10sXEhzFRSnvFcl3XxNGhnD4N2SedqwdAvK3dsihxVUA/edit#heading=h.2ye70wns7io3).
|
||||
|
||||
Installation is simple:
|
||||
```
|
||||
@@ -63,7 +66,7 @@ You can download and install Bullet using the [vcpkg](https://github.com/Microso
|
||||
cd vcpkg
|
||||
./bootstrap-vcpkg.sh
|
||||
./vcpkg integrate install
|
||||
vcpkg install bullet3
|
||||
./vcpkg install bullet3
|
||||
|
||||
The Bullet port in vcpkg is kept up to date by Microsoft team members and community contributors. If the version is out of date, please [create an issue or pull request](https://github.com/Microsoft/vcpkg) on the vcpkg repository.
|
||||
|
||||
@@ -91,9 +94,9 @@ p.connect(p.SHARED_MEMORY) #or (p.TCP, "localhost", 6667) or (p.UDP, "192.168.86
|
||||
Make sure cmake is installed (sudo apt-get install cmake, brew install cmake, or https://cmake.org)
|
||||
|
||||
In a terminal type:
|
||||
|
||||
./build_cmake_pybullet_double.sh
|
||||
|
||||
```
|
||||
./build_cmake_pybullet_double.sh
|
||||
```
|
||||
This script will invoke cmake and build in the build_cmake directory. You can find pybullet in Bullet/examples/pybullet.
|
||||
The BulletExampleBrowser binary will be in Bullet/examples/ExampleBrowser.
|
||||
|
||||
@@ -101,15 +104,15 @@ You can also build Bullet using premake. There are premake executables in the bu
|
||||
Depending on your system (Linux 32bit, 64bit or Mac OSX) use one of the following lines
|
||||
Using premake:
|
||||
```
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
cd build3
|
||||
./premake4_linux --double gmake
|
||||
./premake4_linux64 --double gmake
|
||||
./premake4_osx --double --enable_pybullet gmake
|
||||
```
|
||||
Then
|
||||
```
|
||||
cd gmake
|
||||
make
|
||||
cd gmake
|
||||
make
|
||||
```
|
||||
|
||||
Note that on Linux, you need to use cmake to build pybullet, since the compiler has issues of mixing shared and static libraries.
|
||||
@@ -117,9 +120,9 @@ Note that on Linux, you need to use cmake to build pybullet, since the compiler
|
||||
**Mac OSX Xcode**
|
||||
|
||||
Click on build3/xcode4.command or in a terminal window execute
|
||||
|
||||
./premake_osx xcode4
|
||||
|
||||
```
|
||||
./premake_osx xcode4
|
||||
```
|
||||
## Usage
|
||||
|
||||
The App_ExampleBrowser executables will be located in the bin folder.
|
||||
|
||||
@@ -149,7 +149,7 @@ ELSE()
|
||||
IF(NOT APPLE)
|
||||
FIND_PACKAGE(Threads)
|
||||
TARGET_LINK_LIBRARIES( App_HelloBulletRobotics ${CMAKE_THREAD_LIBS_INIT} ${DL} )
|
||||
ENDIF(APPLE)
|
||||
ENDIF(NOT APPLE)
|
||||
ENDIF(WIN32)
|
||||
|
||||
|
||||
|
||||
@@ -56,7 +56,7 @@ class MinitaurEnvRandomizer(env_randomizer_base.EnvRandomizerBase):
|
||||
leg_masses_upper_bound = np.array(leg_masses) * (1.0 + self._minitaur_leg_mass_err_range[1])
|
||||
randomized_leg_masses = [
|
||||
np.random.uniform(leg_masses_lower_bound[i], leg_masses_upper_bound[i])
|
||||
for i in xrange(len(leg_masses))
|
||||
for i in range(len(leg_masses))
|
||||
]
|
||||
minitaur.SetLegMasses(randomized_leg_masses)
|
||||
|
||||
|
||||
2
setup.py
2
setup.py
@@ -501,7 +501,7 @@ if 'BT_USE_EGL' in EGL_CXX_FLAGS:
|
||||
|
||||
setup(
|
||||
name='pybullet',
|
||||
version='3.1.4',
|
||||
version='3.1.5',
|
||||
description=
|
||||
'Official Python Interface for the Bullet Physics SDK specialized for Robotics Simulation and Reinforcement Learning',
|
||||
long_description=
|
||||
|
||||
@@ -1294,9 +1294,7 @@ public:
|
||||
btVector3 normalColor(1, 1, 0);
|
||||
m_debugDrawer->drawLine(center, center + normal, normalColor);
|
||||
}
|
||||
m_debugDrawer->drawLine(wv0, wv1, m_color);
|
||||
m_debugDrawer->drawLine(wv1, wv2, m_color);
|
||||
m_debugDrawer->drawLine(wv2, wv0, m_color);
|
||||
m_debugDrawer->drawTriangle(wv0, wv1, wv2, m_color, 1.0);
|
||||
}
|
||||
};
|
||||
|
||||
|
||||
@@ -405,6 +405,10 @@ void btDeformableBodySolver::predictMotion(btScalar solverdt)
|
||||
for (int i = 0; i < m_softBodies.size(); ++i)
|
||||
{
|
||||
btSoftBody* psb = m_softBodies[i];
|
||||
/* Clear contacts */
|
||||
psb->m_nodeRigidContacts.resize(0);
|
||||
psb->m_faceRigidContacts.resize(0);
|
||||
psb->m_faceNodeContacts.resize(0);
|
||||
|
||||
if (psb->isActive())
|
||||
{
|
||||
@@ -472,10 +476,6 @@ void btDeformableBodySolver::predictDeformableMotion(btSoftBody* psb, btScalar d
|
||||
{
|
||||
psb->updateFaceTree(true, true);
|
||||
}
|
||||
/* Clear contacts */
|
||||
psb->m_nodeRigidContacts.resize(0);
|
||||
psb->m_faceRigidContacts.resize(0);
|
||||
psb->m_faceNodeContacts.resize(0);
|
||||
/* Optimize dbvt's */
|
||||
// psb->m_ndbvt.optimizeIncremental(1);
|
||||
// psb->m_fdbvt.optimizeIncremental(1);
|
||||
|
||||
@@ -4,8 +4,8 @@ Copyright (c) 2003-2009 Erwin Coumans http://bulletphysics.org
|
||||
|
||||
This software is provided 'as-is', without any express or implied warranty.
|
||||
In no event will the authors be held liable for any damages arising from the use of this software.
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
Permission is granted to anyone to use this software for any purpose,
|
||||
including commercial applications, and to alter it and redistribute it freely,
|
||||
subject to the following restrictions:
|
||||
|
||||
1. The origin of this software must not be misrepresented; you must not claim that you wrote the original software. If you use this software in a product, an acknowledgment in the product documentation would be appreciated but is not required.
|
||||
@@ -21,7 +21,7 @@ subject to the following restrictions:
|
||||
|
||||
///The btIDebugDraw interface class allows hooking up a debug renderer to visually debug simulations.
|
||||
///Typical use case: create a debug drawer object, and assign it to a btCollisionWorld or btDynamicsWorld using setDebugDrawer and call debugDrawWorld.
|
||||
///A class that implements the btIDebugDraw interface has to implement the drawLine method at a minimum.
|
||||
///A class that implements the btIDebugDraw interface will need to provide non-empty implementations of the the drawLine and getDebugMode methods at a minimum.
|
||||
///For color arguments the X,Y,Z components refer to Red, Green and Blue each in the range [0..1]
|
||||
class btIDebugDraw
|
||||
{
|
||||
|
||||
Reference in New Issue
Block a user